
Physical AI startup RLWRLD (RLWRLD) will secure investment from Nvidia. It plans to use the funding to upgrade its robotics foundation model and broaden deployment at industrial sites.
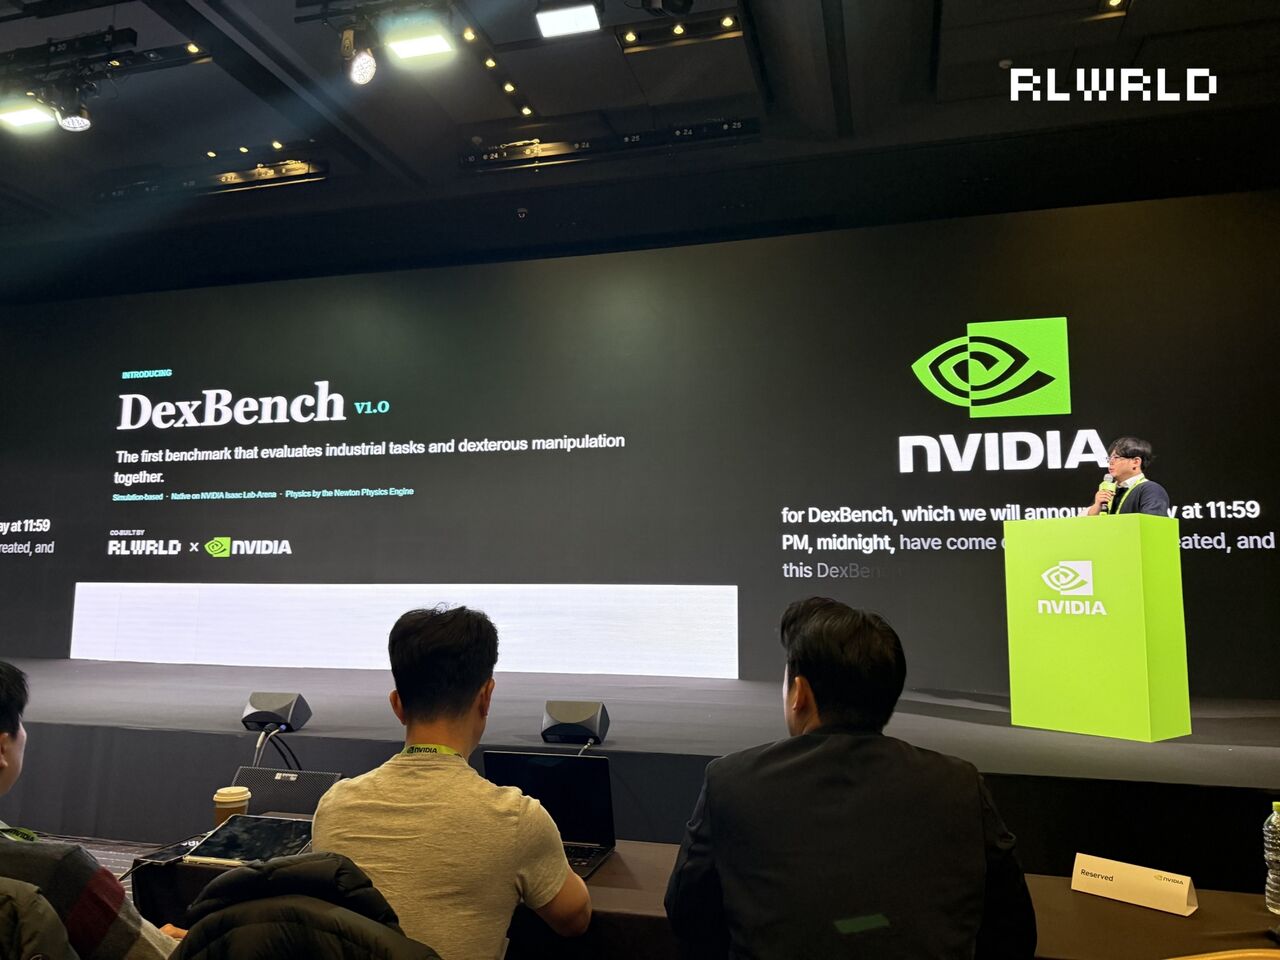
RLWRLD said on Nov. 9 it officially confirmed Nvidia's investment plan announced at "Nvidia AI Day Seoul 2026" held at COEX in Seoul. The company did not disclose the size of the investment.
RLWRLD also unveiled DexBench, a benchmark for evaluating humanoid robots' precise hand manipulation capabilities.
DexBench is a set of evaluation criteria and data standards for precise robotic hand manipulation that RLWRLD developed in cooperation with Nvidia in June. It was built on Nvidia's robot simulation platform Isaac Lab-Arena and the open-source physics engine Newton.
DexBench implements 15 tasks, including product placement, unloading goods, connector insertion and screw fastening, across 4 industrial environments: retail and logistics, assembly, and hotel food and beverage. RLWRLD explained that it can evaluate not only a robot's task success rate but also generalisation performance, or its ability to manipulate objects or environments it has not learned.
RLWRLD plans to release DexBench code, evaluation environments, training data and a performance comparison leaderboard.
RLWRLD CEO Ryu Jung-hee (류중희) said, "To connect progress in robot AI with adoption in real sites, it must be possible to objectively measure robots' precision manipulation capabilities in actual industrial environments." He said, "DexBench is the first concrete result of working with Nvidia and industry and technology partners to build this evaluation foundation."
 Seulgi Son
sageson@d-today.co.kr