
Physical AI company RealWorld has proposed a “deployment-first” strategy that moves away from the conventional approach of completing technology in a laboratory and then applying it in industrial sites. Under the approach, real-world deployment becomes the starting point for advancing the technology.
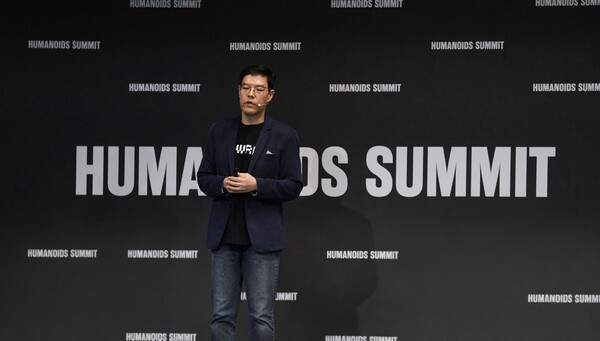
RealWorld took part as an official technology partner in the Humanoid Summit Seoul 2026, held at Coex in Seoul from Sept. 22 for two days. It said on Tuesday it presented a physical AI development strategy that advances robots’ manipulation capabilities with data gathered from actual industrial sites and links those gains back to field deployment.
RealWorld CEO Joonghee Ryu (류중희) presented the virtuous cycle connecting field deployment, industrial data and hand manipulation capability, or dexterity, as a core strategy in a keynote speech titled “Solving the five-finger dexterity problem: RealWorld’s approach to industrial-grade dexterity.”
Ryu said deploying robots in real industrial sites first allows the accumulation of work data that is hard to obtain in research settings. As models trained on that data improve manipulation capability, the range of applications can expand to more complex and diverse sites.
Based on this, RealWorld defines itself as a “field deployment-first frontier lab.” It focuses on continuously improving the performance of models and robots by starting with problems and data that arise in industrial sites, rather than completing research results and then moving them into the field.
It has also set dexterity technology as a key task for performing precise work in real industrial environments, such as grasping and moving objects. In complex sites, it said, robots need the ability to precisely manipulate their hands in response to changes in objects and the work environment, beyond repeating predetermined motions.
RealWorld Chief Strategy Officer Jiyoon Ahn (안지윤) delivered a presentation titled “Scaling fine manipulation in the real world.” Ahn introduced a development direction that continually advances robots’ manipulation capability based on data secured in the field and expands it across different robot hardware and work environments.
To that end, RealWorld is developing a robotics foundation model, or RFM, that learns industrial-site data to implement robot manipulation capability and can be extended across diverse hardware and work environments. At the event, it also showcased object manipulation technology for a five-finger robot hand applying the RFM “RealDexOne (RLDX-1).”
 Seulgi Son
sageson@d-today.co.kr